
Autonomous Patroller
An autonomous security robot that maps a site, patrols on a schedule, detects people with YOLO and decides when to escalate. I founded Stratos AI & Robotics to take it from simulation to Nigerian banks and facilities.
4Subsystems: SLAM, Nav2, vision, decisions
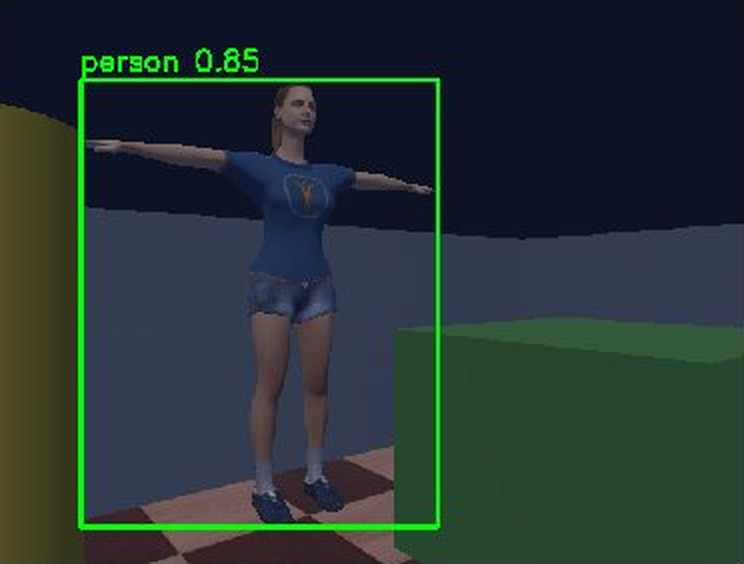
0.85Person-detection confidence
DoneAll simulation phases
NextPhysical MVP
01The problem
The problem
Night security for offices, banks and warehouses is costly to staff and hard to audit. A robot can cover a fixed route consistently, log what it sees and escalate only what matters.
02How it’s built
How it’s built
- ROS 2 Jazzy with Webots, Webots on Windows and ROS 2 in WSL Ubuntu 24.04.
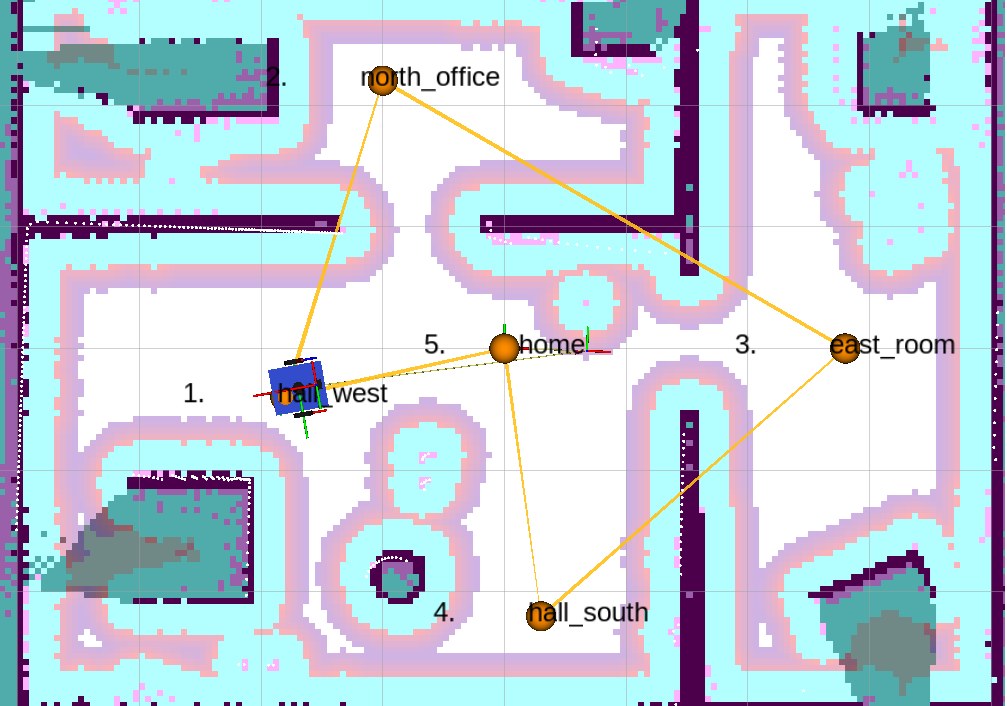
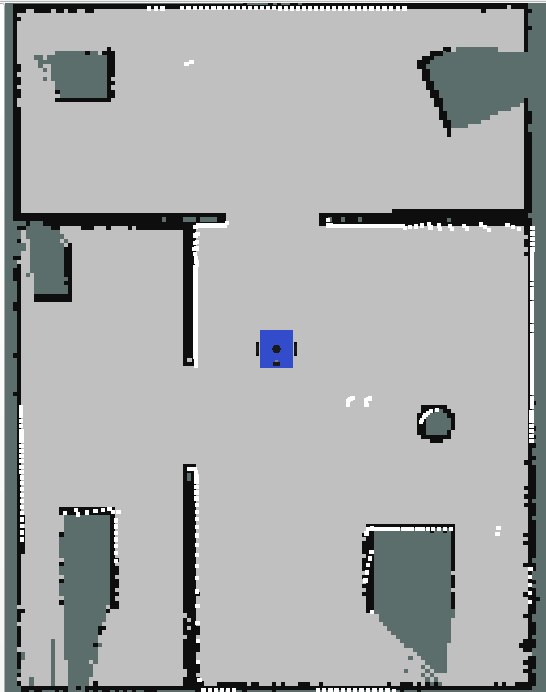
- LiDAR, odometry and SLAM build the site map. Nav2 runs a looping patrol through named waypoints: hall west, north office, east room, hall south and home.
- I rebuilt the world at realistic office scale with a larger robot and a mast camera before adding perception, then remapped and retuned Nav2.
- YOLO person detection runs on the mast camera feed.
03Decisions
Decisions
- Schedule-based zones decide what counts as an intrusion at a given time.
- Staged escalation separates a passing employee from a real event.
- Personal space: the robot keeps its distance and steps back when approached.
- Alerts go to a FastAPI service. A production API and mobile dashboard are planned.
04From project to company
From project to company
I founded Stratos AI & Robotics to take the Patroller to market, with Standard and Premium tiers for Nigerian facilities and banks. The physical MVP is the next milestone.